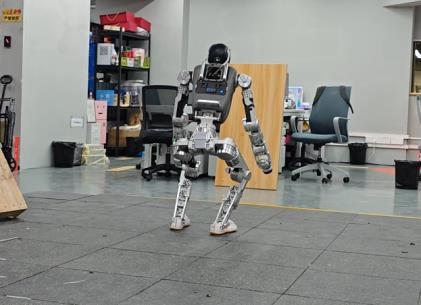
The BXI-70 covers the workhorse joints of a humanoid robot: leg yaw, waist, elbows and shoulders. It bridges the gap between the compact BXI-50 and the high-torque BXI-85 with the same hollow-shaft design, dual encoders and MIT-protocol control.
Specifications
| Item | Specification |
|---|---|
| Rated torque | 15 N·m |
| Peak torque | 50 N·m |
| Peak current | 60 A |
| Outer diameter | 81 mm |
| Height | 66.5 mm |
| Hollow shaft | 9 mm |
| Weight | 0.8 kg |
| Supply voltage | 24–48 V |
| Communication | CAN / CAN FD |
| Control | MIT protocol; torque / position / velocity hybrid |
Typical joint placements
- Leg yaw and waist — smooth turning and torso rotation
- Elbow and shoulder — responsive arm motion for manipulation and gesturing
Designed for ODM integration
With a 9 mm hollow shaft and standardized CAN FD MIT interface, BXI-70 integrates cleanly into custom arm and torso designs. As an ODM customer you get the full mechanical drawings, driver firmware and ROS 2 integration support.
Ready to build a humanoid robot under your own brand?
Get a Quote