Multi-Joint Control Unit: A Real-Time Robot Brain at 1 kHz
FPGA-based real-time control of 60+ joints at 1,000 Hz, with NUC i7 or RK3588 compute, HiPNUC IMU and an open software stack on Ubuntu 22.04.
Read more →
BXI Gripper: Lightweight Parallel Gripper for Humanoid Robots
A 1-DoF parallel gripper under 500 g with 100 mm fingers, up to 100 N grip force, driven by the BXI-50 actuator and compatible with third-party dexterous hands.
Read more →
BXI-50 Joint Actuator: Compact 25 N·m Peak with 6 mm Hollow Shaft
BXI-50 packs 7 N·m rated / 25 N·m peak torque, 200 RPM no-load speed and dual encoders into a 64 mm, 0.5 kg module for wrists, ankles and head-neck joints.
Read more →
BXI-70 Joint Actuator: 15 N·m Rated, 50 N·m Peak Torque
BXI-70 is the mid-torque member of the BXI family — 15 N·m rated, 50 N·m peak, 60 A peak current — for leg yaw, waist, elbow and shoulder joints.
Read more →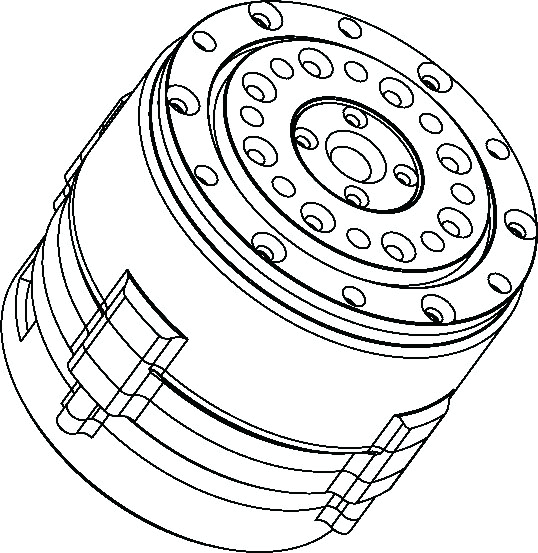
BXI-85 Joint Actuator: 40 N·m Rated, 150 N·m Peak Torque
BXI-85 delivers 40 N·m rated and 150 N·m peak torque for knees, thighs, waist and heavy-payload arm shoulders, with a 10 mm hollow shaft and dual encoders.
Read more →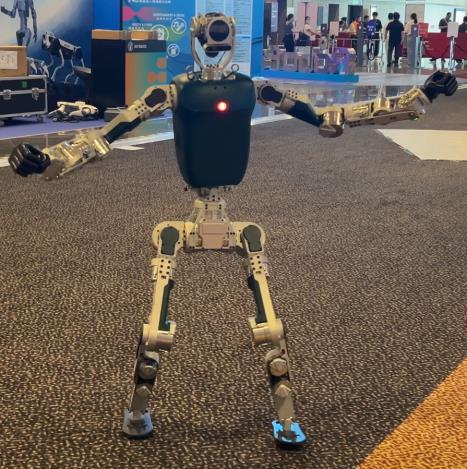
Ludu 3: Full-Size Humanoid Robot Platform
145 cm, 31 DoF, up to 5 m/s. Ludu 3 is a production-ready full-size humanoid robot platform with hollow-routing joints, dual encoders, a ROS 2 SDK and an RL-trained motion stack.
Read more →